Articles | Volume 14, issue 1
https://doi.org/10.5194/ms-14-19-2023
Research article
 | 
30 Jan 2023
Research article |  | 30 Jan 2023

Modeling and control strategy of a haptic interactive robot based on a cable-driven parallel mechanism

Da Song, Xinlei Xiao, Gang Li, Lixun Zhang, Feng Xue, and Lailu Li

Related authors

Design and analysis of a novel cable-driven parallel robot with variable stiffness and rigid–flexible coupling
Yutong Wu, Xinlei Xiao, Haochen Wang, and Da Song
Mech. Sci., 17, 917–933, https://doi.org/10.5194/ms-17-917-2026,https://doi.org/10.5194/ms-17-917-2026, 2026
Short summary
Error modelling and experimental validation for a new-type series-parallel stable platform
Xinlei Xiao, Da Song, Yanda Jiang, Bo Cui, Lixun Zhang, and Feng Xue
Mech. Sci., 16, 657–671, https://doi.org/10.5194/ms-16-657-2025,https://doi.org/10.5194/ms-16-657-2025, 2025
Short summary
Modeling and control system experiment of a novel series three-axis stable platform
Da Song, Xinlei Xiao, Ji Ma, and Lixun Zhang
Mech. Sci., 15, 209–221, https://doi.org/10.5194/ms-15-209-2024,https://doi.org/10.5194/ms-15-209-2024, 2024
Short summary
Download
Short summary
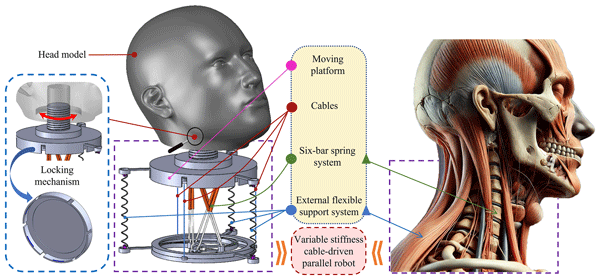
The haptic interactive robot based on a cable-driven parallel mechanism studied in this paper is mainly used for interactive training between an astronaut and a virtual environment. This haptic interactive robot can accurately simulate the motion and mechanical characteristics of objects in a microgravity environment and can safely interact with astronauts.
Share