Articles | Volume 15, issue 1
https://doi.org/10.5194/ms-15-209-2024
© Author(s) 2024. This work is distributed under
the Creative Commons Attribution 4.0 License.
https://doi.org/10.5194/ms-15-209-2024
© Author(s) 2024. This work is distributed under
the Creative Commons Attribution 4.0 License.
Modeling and control system experiment of a novel series three-axis stable platform
Da Song
School of Mechanical Engineering, Northeast Electric Power University, Jilin 132012, PR China
School of Mechanical and Civil Engineering, Jilin Agricultural Science and Technology University, Jilin 132101, PR China
Ji Ma
704 Institute of China Aerospace Science and Technology Corporation, Beijing 100076, PR China
Lixun Zhang
College of Mechanical and Electrical Engineering, Harbin Engineering University, Harbin 150001, PR China
Related authors
Yutong Wu, Xinlei Xiao, Haochen Wang, and Da Song
Mech. Sci., 17, 917–933, https://doi.org/10.5194/ms-17-917-2026, https://doi.org/10.5194/ms-17-917-2026, 2026
Short summary
Short summary
This study presents a novel cable-driven parallel robot integrated with rigid–flexible coupling and a variable stiffness system, specifically designed to replicate the motion characteristics of the human cervical spine. Kinematic control of the robot is achieved by establishing a functional relationship between its configuration space and actuation space.
Xinlei Xiao, Da Song, Yanda Jiang, Bo Cui, Lixun Zhang, and Feng Xue
Mech. Sci., 16, 657–671, https://doi.org/10.5194/ms-16-657-2025, https://doi.org/10.5194/ms-16-657-2025, 2025
Short summary
Short summary
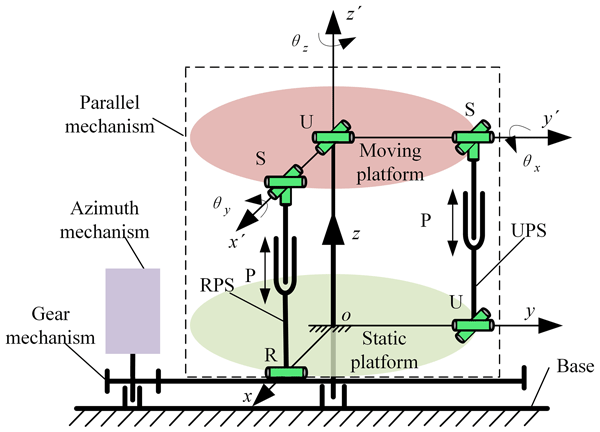
This article designs a three-degrees-of-freedom (3-DoF) series-parallel stabilisation platform (SPSP), analyses the platform's degrees of freedom, establishes an error model, and analyses the degree to which each error affects the attitude error of the moving platform when inputting a sine signal, as well as the degree to which each error source affects the attitude error of the moving platform at a certain attitude.
Da Song, Xinlei Xiao, Gang Li, Lixun Zhang, Feng Xue, and Lailu Li
Mech. Sci., 14, 19–32, https://doi.org/10.5194/ms-14-19-2023, https://doi.org/10.5194/ms-14-19-2023, 2023
Short summary
Short summary
The haptic interactive robot based on a cable-driven parallel mechanism studied in this paper is mainly used for interactive training between an astronaut and a virtual environment. This haptic interactive robot can accurately simulate the motion and mechanical characteristics of objects in a microgravity environment and can safely interact with astronauts.
Short summary
In this paper, a novel series three-axis stable platform (STSP) is proposed, and its azimuth angle structure, pitch angle structure, roll angle structure, system control scheme, and control strategy are designed. The main function of this stable platform is to isolate the influence of installation carrier movement or external interference and to provide a stable working environment for equipment installed on the stable platform by establishing a stable reference plane.
In this paper, a novel series three-axis stable platform (STSP) is proposed, and its azimuth...