Articles | Volume 13, issue 1
https://doi.org/10.5194/ms-13-1-2022
Research article
 | 
07 Jan 2022
Research article |  | 07 Jan 2022

Bionic design and analysis of a multi-posture wheelchair

Qiaoling Meng, Mingpeng Jiang, Zongqi Jiao, and Hongliu Yu

Related authors

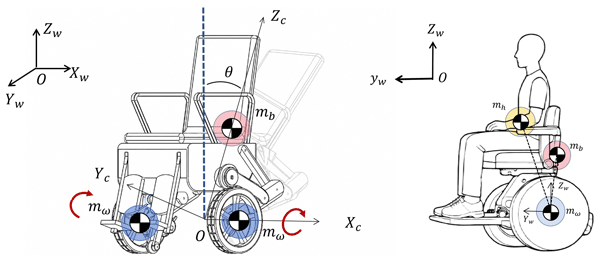
Hybrid nonlinear model predictive and linear quadratic balance control for a two-wheeled self-balancing wheelchair
Haomin Sun, Xinying Zhang, Yaozhi Gu, Shuai Wang, Weiyue Chen, Shuyue Zhang, Tianyu Xu, Hongliu Yu, and Qiaoling Meng
Mech. Sci., 17, 713–729, https://doi.org/10.5194/ms-17-713-2026,https://doi.org/10.5194/ms-17-713-2026, 2026
Short summary
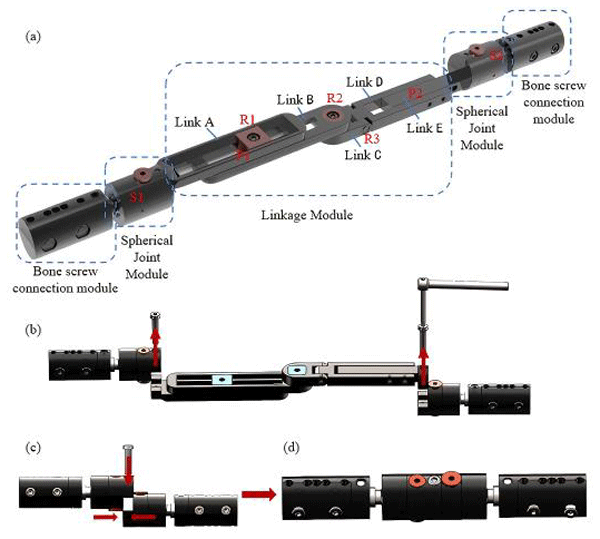
A reconfigurable seven-link multi-mode external-fixation system for improving emergency limb fracture stabilization efficiency
Cuizhi Fei, Zongqi Jiao, Qiaoling Meng, Bangke Zhang, and Xuhua Lu
Mech. Sci., 17, 453–467, https://doi.org/10.5194/ms-17-453-2026,https://doi.org/10.5194/ms-17-453-2026, 2026
Short summary
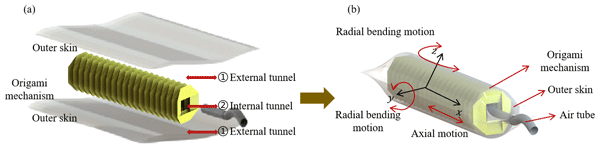
Design and validation of a programmable dual-tunnel soft pneumatic origami actuator with a large maximum shrinkage rate for reciprocating motion
Rongna Xu, Qiaoling Meng, Qiaolian Xie, Yuxin Zheng, Cuizhi Fei, Vincenzo Parenti Castelli, and Hongliu Yu
Mech. Sci., 16, 61–73, https://doi.org/10.5194/ms-16-61-2025,https://doi.org/10.5194/ms-16-61-2025, 2025
Short summary
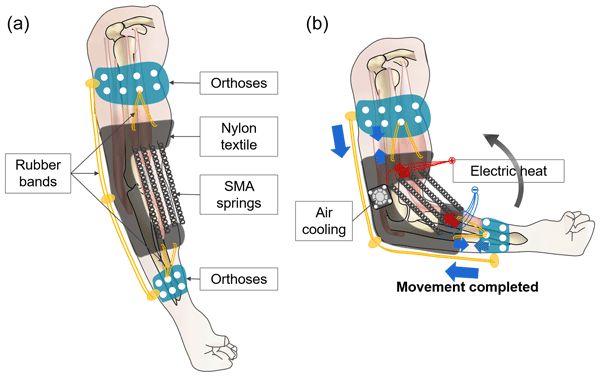
Design of a soft bionic elbow exoskeleton based on shape memory alloy spring actuators
Qiaolian Xie, Qiaoling Meng, Wenwei Yu, Rongna Xu, Zhiyu Wu, Xiaoming Wang, and Hongliu Yu
Mech. Sci., 14, 159–170, https://doi.org/10.5194/ms-14-159-2023,https://doi.org/10.5194/ms-14-159-2023, 2023
Short summary
Electromyogram-based motion compensation control for the upper limb rehabilitation robot in active training
Qiaoling Meng, Yiming Yue, Sujiao Li, and Hongliu Yu
Mech. Sci., 13, 675–685, https://doi.org/10.5194/ms-13-675-2022,https://doi.org/10.5194/ms-13-675-2022, 2022
Short summary
Download
Short summary
This paper proposes a bionic, multi-posture wheelchair, based on the proposed human–wheelchair coupling model, according to the movement characteristics and requirements. The two key factors in designing the multi-posture wheelchair, the consistency of the motion center and the compensation of the shifting center of gravity, are analyzed in this paper. The novel multi-posture wheelchair can implement the sit-to-lie and sit-to-stand transformations with a maximum slipping distance of 10.5 mm.
Share